 Germany
The Challenge
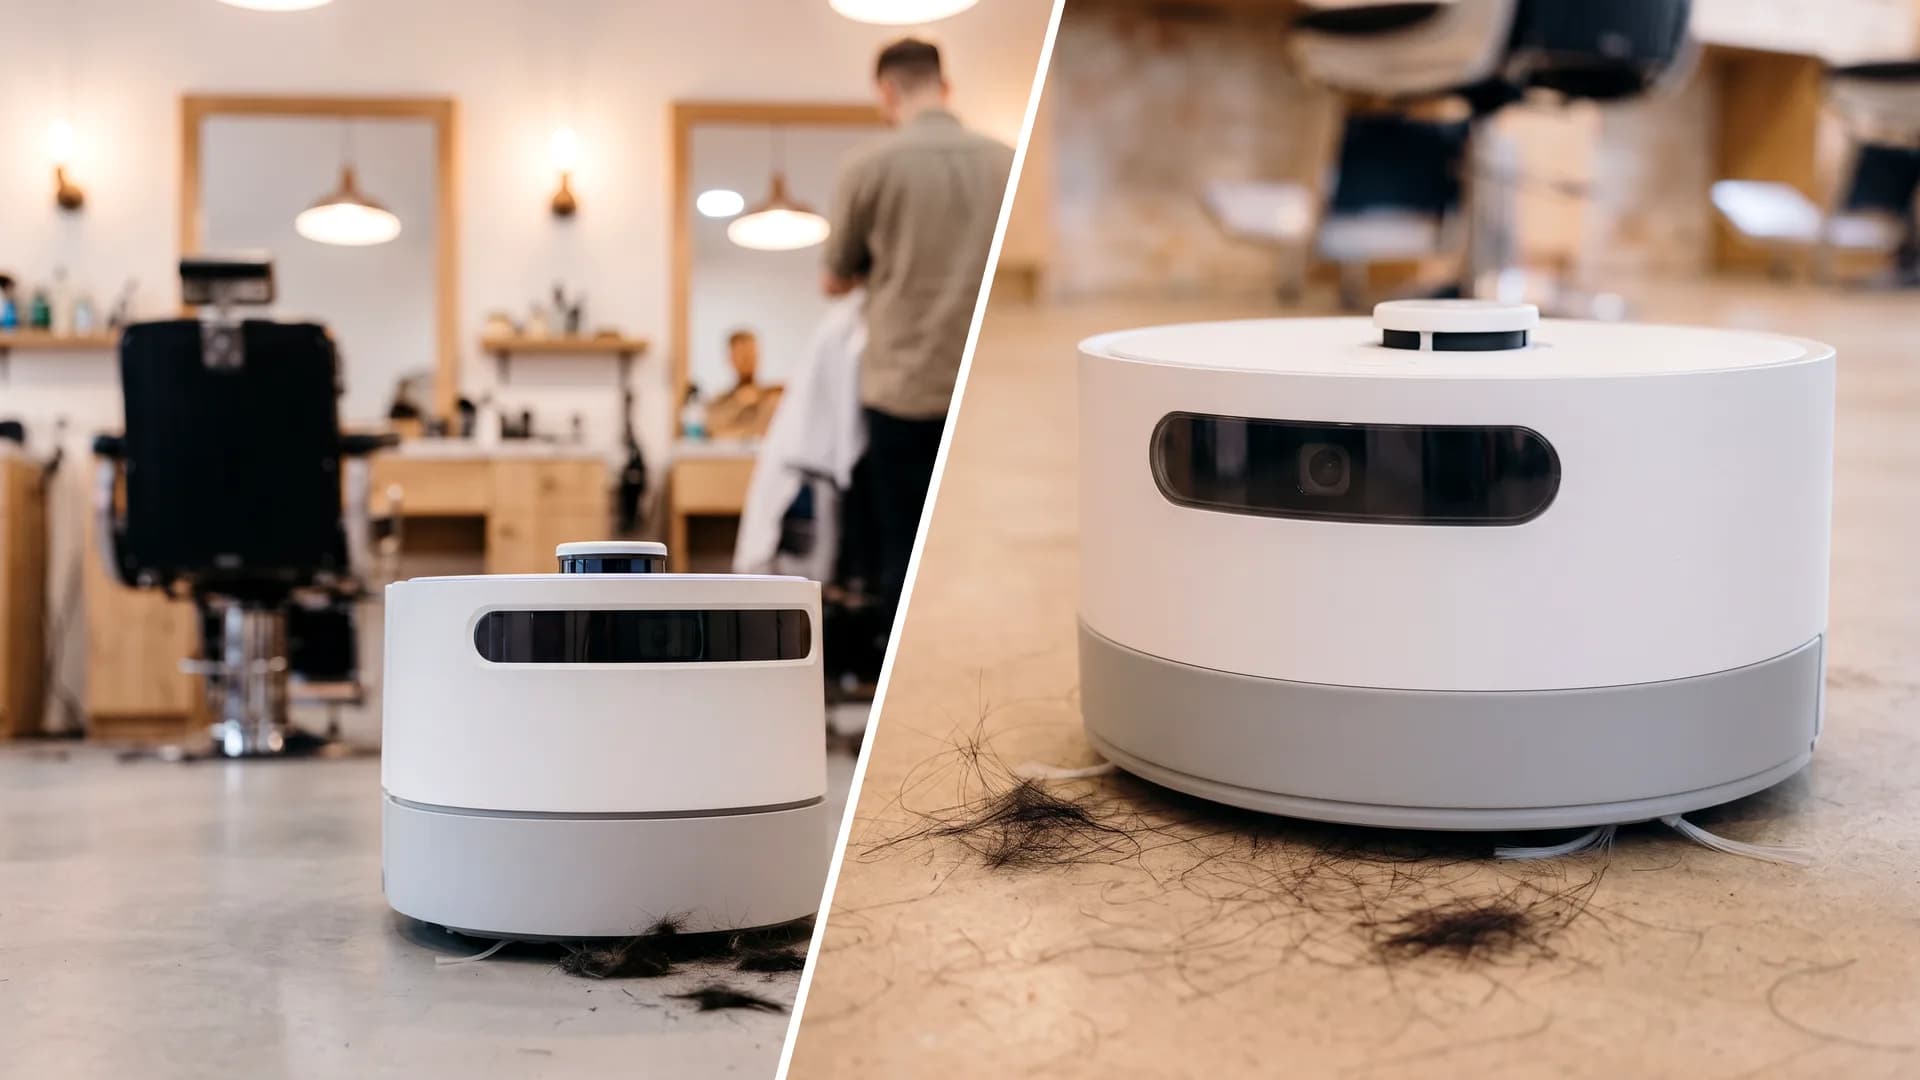
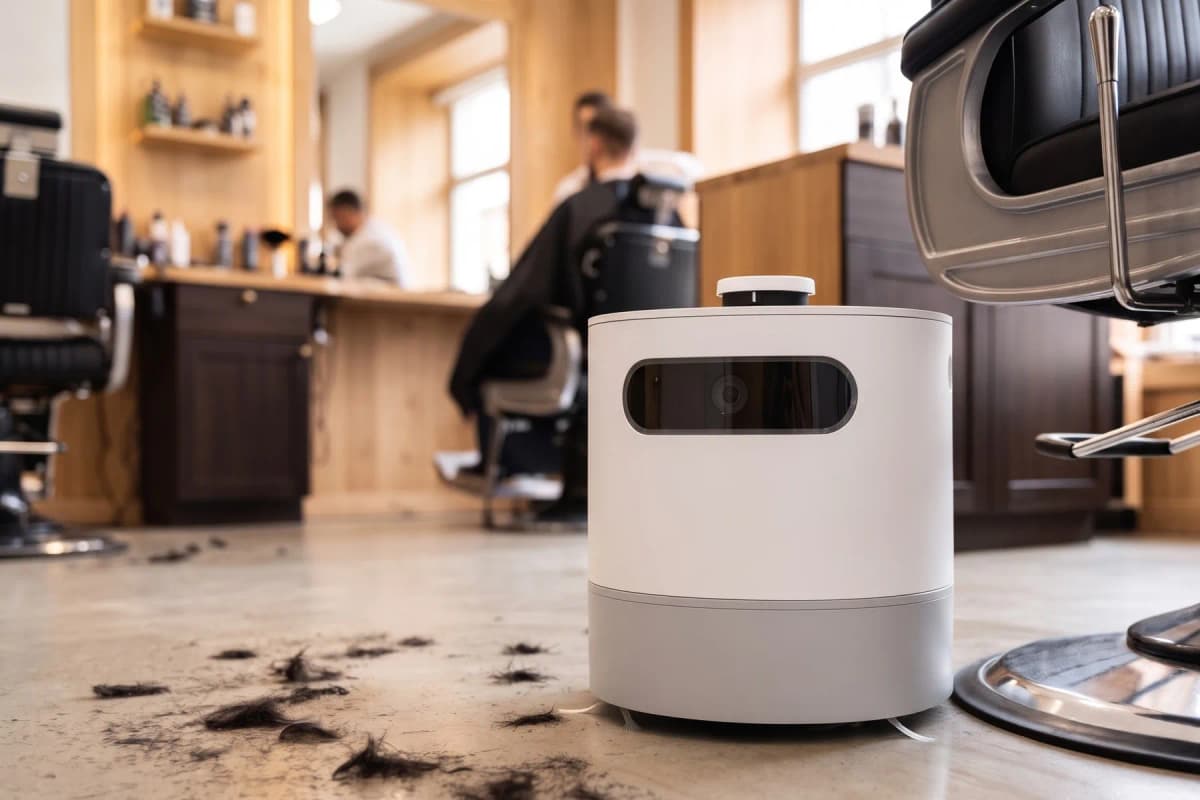
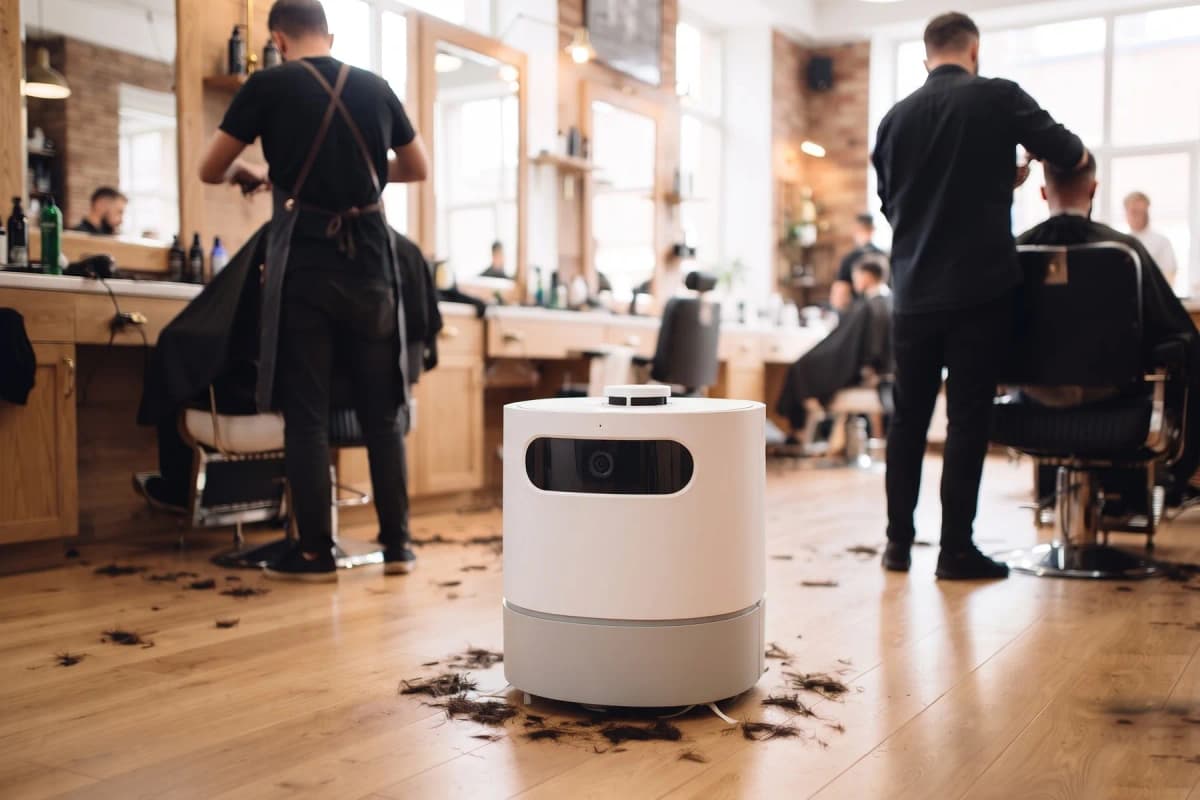
Salons and barbershops sweep up cut hair all day. The client is building a robot that keeps the floor clean on its own, and needed an engineering team that could turn its design into a working machine quickly.
It had to be built fast, follow the client's design closely, and be ready for the next stages of development.
The Solution
Phase 1: we designed the robot's base in 3D from scratch, fabricated it, and built the drive, power and sensing system into it: a 360° LiDAR for mapping, a 3D depth camera and multi-zone time-of-flight sensors for what sits below the LiDAR's view, and cliff and bump sensors as the last line of safety, all brought together on ROS 2. It ended with a prototype that maps the room, senses its surroundings and drives under control.
Phase 2: we designed the full robot body in 3D, fabricated it, and assembled the complete robot, fitting and correcting every part. The whole build took about two months, done end to end in-house: 3D design, electronics, firmware, fabrication and assembly.
System Architecture
- Step 1Base and driveBase built, with drive, power and sensing integrated.
- Step 2Full bodyThe full robot body designed and fabricated.
- Step 3Prototype deliveredAn assembled robot that drives and senses its surroundings.
Under the hood
- 360° LiDAR for SLAM mapping and localisation around chairs and stations
- 3D depth camera to see obstacles in front of the robot
- Multi-zone time-of-flight sensors covering the floor below the LiDAR plane
- Cliff sensors for mat edges and drops; wheel-drop and bump switches
- Side-facing sensor for edge cleaning along chair bases
- ROS 2 on an onboard computer: mapping, navigation and path planning
- Real-time microcontroller for motor control and sensor polling
- micro-ROS bridge between the microcontroller and ROS 2
- Sensor fusion of LiDAR, depth and ToF data into one obstacle picture
- Autonomous docking to side-mounted charging contacts
- Base, chassis and full body designed in 3D from scratch
- Parts fabricated, fitted and assembled in-house, end to end
- Two-wheel differential drive for accurate odometry for SLAM
- Wheels and hubs designed to resist hair wrapping
- Battery power distribution for drive, suction, compute and sensors
Hard problems we solved
Key Capabilities
- Designed in 3D from scratch, then fabricated: base, chassis and body
- Differential drive and battery power integrated and tuned
- Sensor fusion: 360° LiDAR, 3D depth camera, ToF and cliff sensors
- ROS 2 on an onboard computer, with real-time control on a microcontroller
- Full body designed, fabricated and assembled end to end
- Fast iteration with the client's team
Impact
- Built for a robotics client in Germany
- From parts on the bench to a driving, sensing prototype
- Full robot body designed, fabricated and assembled; about two months in total
- Delivered ready for the client's next development stages